
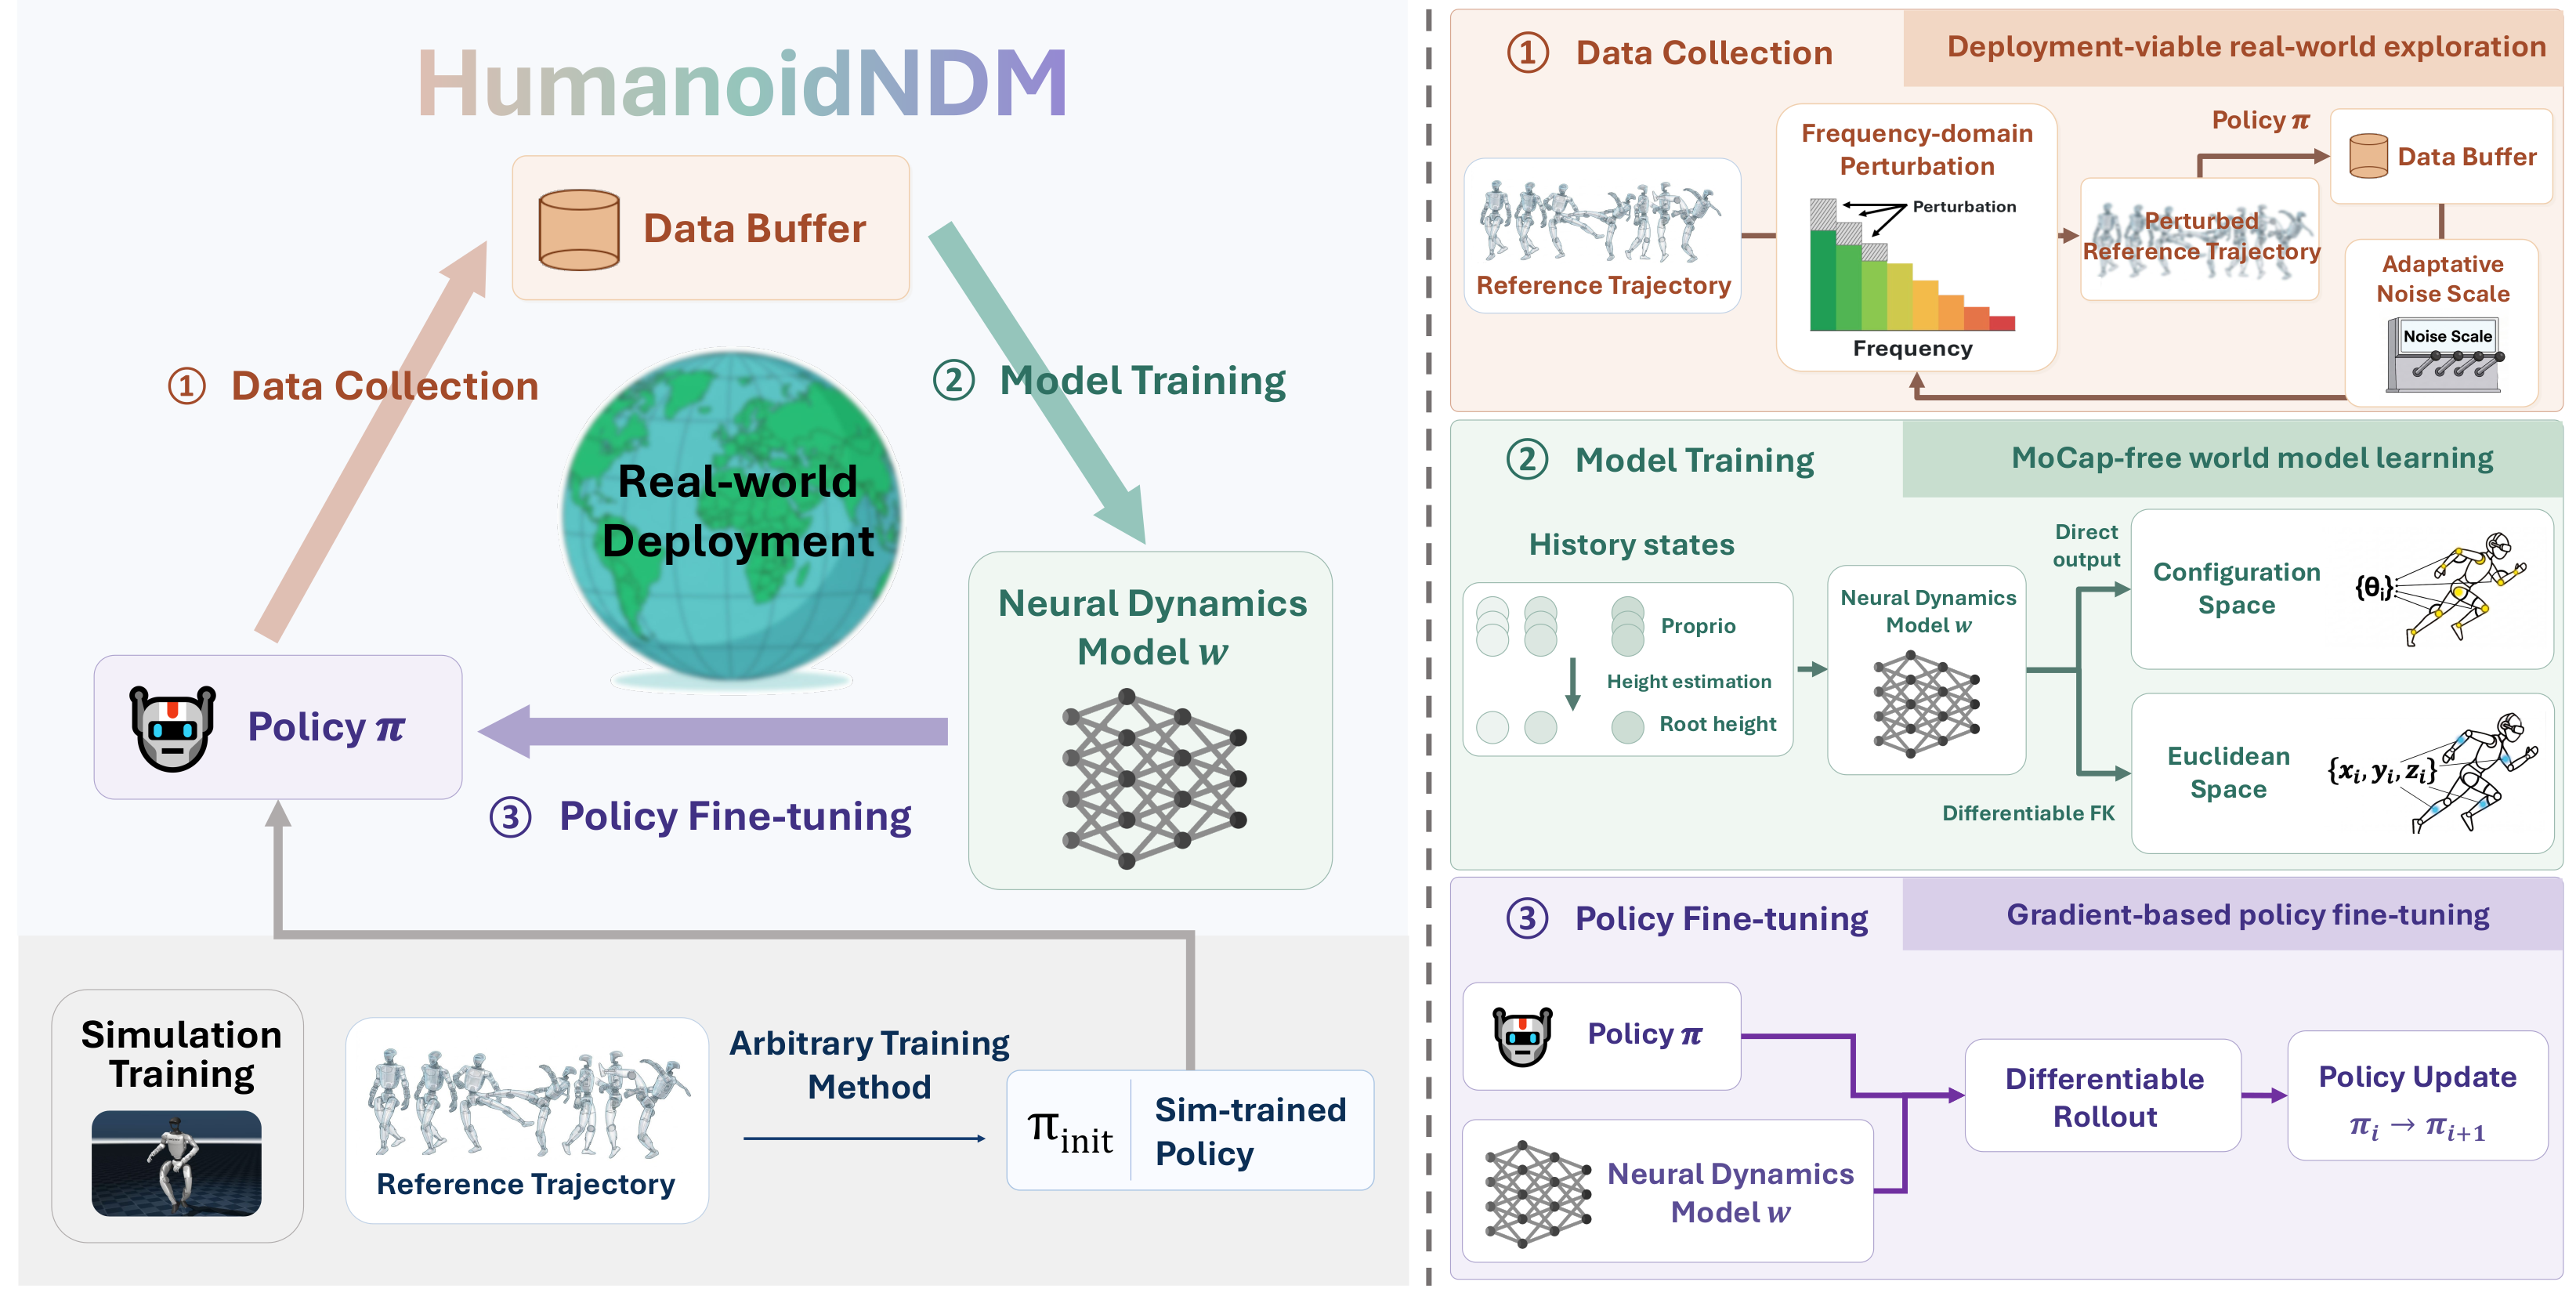
HumanoidNDM: Closing the Training-Deployment Gap of Motion Tracking via Humanoid Neural Dynamics Model
Chao Chen*, Zhenrong Wang*, Jilong Wang, Yusen Feng, Jiangran Lyu, Li Yi, He Wang†
CoRL 2026
We bridge the training-deployment gap in humanoid motion tracking by introducing an online fine-tuning framework.


